Integrating mechanical linear motion into existing programmable logic controller (PLC) topologies has historically introduced unnecessary friction into automation projects. For decades, systems engineers have struggled with outboard motor controllers, third-party signal converters, and fragile custom wiring looms just to execute simple positioning loops or retrieve cycle counts. This fragmented architecture not only introduces latency and points of hardware failure, but also significantly increases engineering hours during design and field commissioning.
Linak’s expansion of its Integrated Controller (IC) actuator lineup directly addresses this edge-integration challenge. By embedding direct industrial fieldbus and Ethernet communication options—including Modbus RTU, Modbus TCP/IP, PROFINET, EtherNet/IP, IO-Link, and CAN interfaces—directly into the actuator chassis, the manufacturer eliminates intermediate transceivers. This shift delivers self-contained, intelligent motion components engineered for modern distributed control architectures.
Native Protocols Replace Protocol Gateways and Hardware Clutter
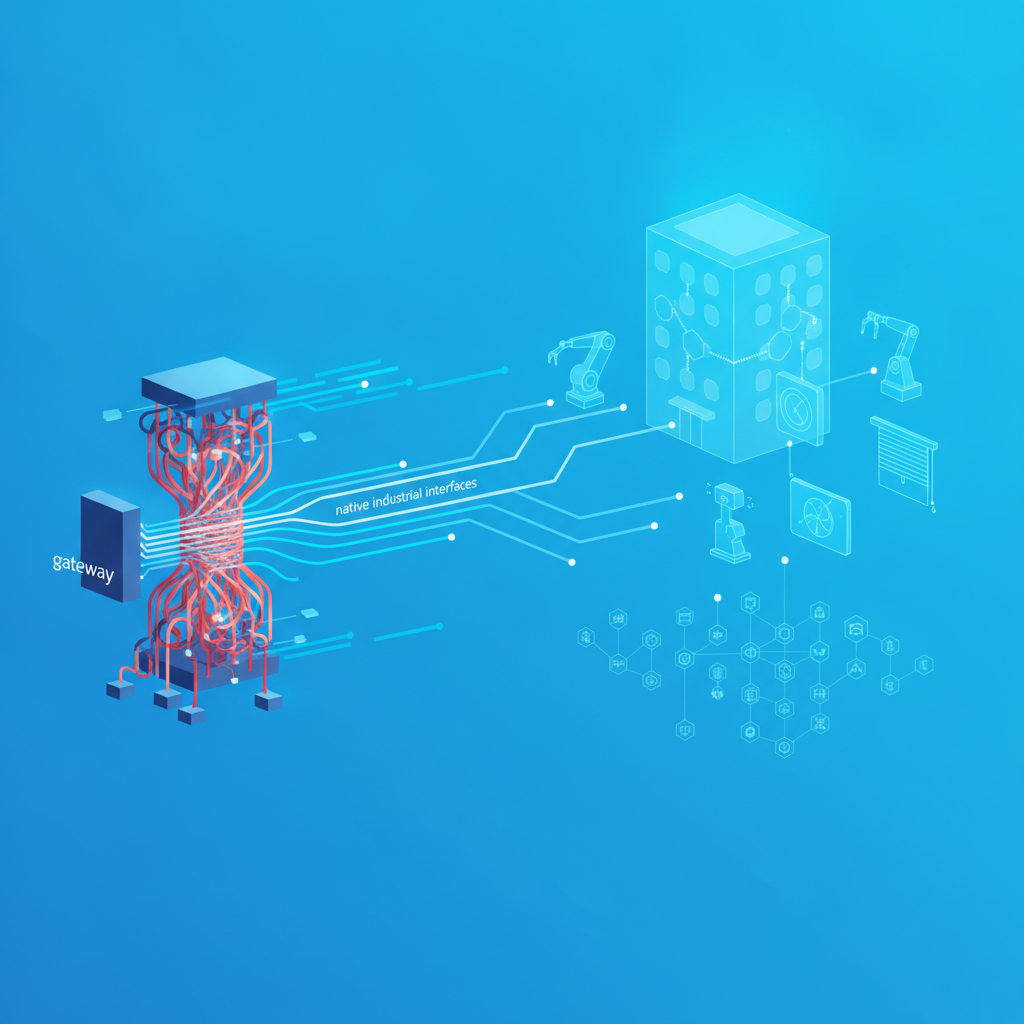
In traditional machine builds and building automation architectures, interfacing physical actuators often demanded dedicated I/O cards or external protocol translators. A control system architect managing a complex Modbus or industrial Ethernet fabric had to allocate cabinet real estate, auxiliary power supplies, and network switch ports solely to translate fieldbus commands into analog 0–10V or pulse-width-modulated (PWM) signals.
By integrating physical interfaces like Modbus TCP/IP, EtherNet/IP, and PROFINET at the device level, linear motion devices transition into true edge nodes. Eliminating intermediary protocol converters simplifies physical installation and substantially tightens device-level ICS security. Unmanaged protocol gateways are notorious attack vectors and points of failure; terminating native, hardened industrial protocols directly at the actuator endpoint minimizes network vulnerabilities and enhances signal fidelity across the automation environment.
Distributed Mechatronics and Embedded Motion Intelligence
Deploying ready-to-integrate actuators does more than just clean up field wiring; it redefines how movement logic is handled between the control layer and the physical layer. With integrated drive electronics, low-level positioning algorithms—such as parallel motor synchronization, run-to-position routines, and soft-start/stop curves—are computed locally inside the actuator housing rather than burdening the main PLC scan cycle.
Crucially, this architecture unleashes continuous bi-directional telemetry. Automation engineers and facility operators receive real-time positioning metrics, dynamic current consumption data, cycle counters, and diagnostic error codes over their protocol of choice. When an actuator detects anomalies such as over-temperature conditions or thermal degradation, it immediately flags alarms across the network before a mechanical jam or catastrophic failure halts operation.
From Field Edge to Scalable Cloud Orchestration
The convergence of standardized fieldbus protocols with distributed mechatronics holds massive implications for scalable smart infrastructure and advanced facilities management. Linear actuators increasingly govern critical physical systems—ranging from dynamic facade shading and specialized high-volume ventilation dampers to industrial cleanroom air locks and critical laboratory containment.
When edge devices communicate natively using open standards such as Modbus TCP/IP, integrating their granular operational metrics into centralized platforms becomes straightforward. Cloud-native ecosystems such as BAaaS.io rely on this continuous telemetry to unify property-wide infrastructure, automate environmental adjustments based on real-time occupancy, and execute proactive maintenance routines. By streaming runtime and mechanical wear telemetry up to BAaaS.io, operators can monitor distributed assets, automate service lifecycles, and optimize energy efficiency without maintaining cumbersome bespoke driver sets at the field layer.
Conclusion
The convergence of smart electronics and heavy-duty mechatronics is transforming field-level hardware from passive mechanical components into intelligent, interconnected edge devices. By embedding a versatile portfolio of industrial interfaces directly into the actuator casing, Linak eliminates the hardware overhead, gateway latency, and custom code that have long frustrated automation engineers.
Moving forward, standardizing on direct, cyber-hardened communication protocols will remain an essential design pattern for both industrial operations and smart buildings. Empowering field-level actuators with autonomous execution and native connectivity lays the foundation for faster deployment cycles, resilient field networks, and effortless integration into enterprise-grade cloud management ecosystems.